How to Choose the Right Miniature Gear Motor?

Time:2026-09-08 Author:Madeline
0%

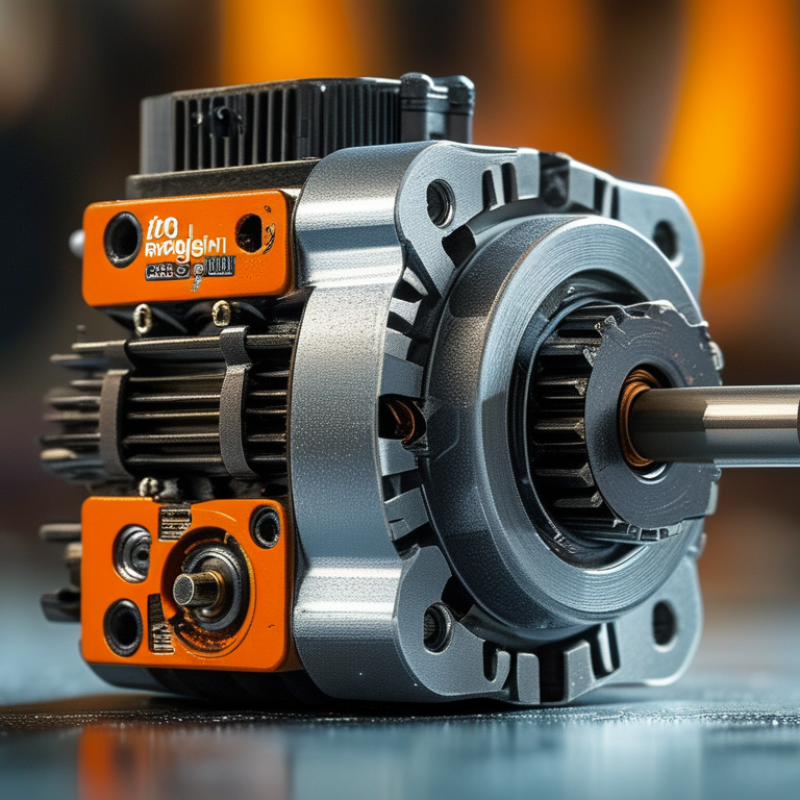
Choosing the right Miniature Gear Motor begins with the application, not the catalogue page. A compact motor may look ideal, yet fail under continuous load, repeated starts, or unexpected friction. Consider the available voltage, required speed, output torque, duty cycle, noise limit, and installation space. Measure the real load if possible. Guesswork is cheaper at the beginning, but expensive after assembly.

Eugen Elmiger, former CEO of maxon, expresses a useful engineering principle: “The drive must serve the application, not the other way around.” This idea keeps selection practical. A robot joint, medical pump, camera mechanism, and automated lock need different motor characteristics. Gear ratio matters, but it is not the whole decision. Efficiency, backlash, shaft orientation, gearbox material, thermal performance, and expected service life also deserve attention. Tiny dimensions can hide serious heat problems.

Start with the hardest operating condition. Not the easiest one.

For example, a motor lifting a 300-gram mechanism may need much more torque during startup than during steady movement. Calculate the torque margin carefully, then verify it through testing. A spreadsheet can reveal the answer. It can also create false confidence when friction, vibration, or misalignment is ignored. I have seen compact drive systems meet their speed target and still fail because the gearbox was overloaded during frequent reversals.

This guide explains how to compare motor technology, reduction ratios, operating limits, control requirements, and supplier reliability. The best Miniature Gear Motor is rarely the largest or fastest option. It is the one that performs consistently inside the real mechanical system.

How to Choose the Right Miniature Gear Motor?

Define the Application Requirements for a Miniature Gear Motor

Choosing the right miniature gear motor starts with the application, not the catalog. Define the load, output speed, operating voltage, and available space. Then identify the motion profile. A motor running for three seconds differs greatly from one operating continuously. Record start-up torque, running torque, stall risk, and reversing frequency. These details prevent a small motor from overheating inside a compact enclosure.

According to the International Federation of Robotics’ World Robotics 2024 report, 541,302 industrial robots were installed worldwide in 2023. This growth increases demand for precise, compact motion systems. However, robot statistics do not replace application testing. Measure the real load, including friction and unexpected resistance. Check gearbox backlash, shaft orientation, noise, and thermal rise. Underestimating these factors remains a common engineering mistake.

Tips: Create a simple duty-cycle table before selecting the motor. Include run time, rest time, load changes, and ambient temperature. Compare continuous torque with peak torque, not only the headline value. Use IEC 60034-1 guidance when reviewing motor ratings, and verify enclosure protection under IEC 60529 when dust or moisture exists. I may choose a motor with extra torque for safety, but excessive oversizing can reduce efficiency, increase cost, and waste space. Prototype testing should include several hundred start-stop cycles, because a clean laboratory test can hide real mechanical wear.

How to Choose the Right Miniature Gear Motor?

Define the application requirements before selecting a miniature gear motor. The chart below compares representative output-speed and torque targets for common applications.

Start by identifying the required output speed, continuous and peak torque, duty cycle, available space, noise limit, and power supply. The motor should be selected with sufficient torque margin for startup loads and operating variations.

Match Motor Speed, Torque, and Power to the Mechanical Load

Choosing the right miniature gear motor starts with the load, not the catalog. Measure the force, shaft radius, and required output speed before comparing motors. For a small conveyor, torque equals resisting force multiplied by pulley radius. Add friction, startup resistance, and a safety margin based on real testing. A motor that turns freely on the bench may stall under a cold, heavy load. That difference matters.

Speed and torque must be matched together. A high-speed motor with excessive reduction can deliver torque but waste energy and respond slowly. A low-speed motor may avoid overheating, yet fail to reach the mechanism’s needed cycle time. Check the rated speed, gearbox ratio, and expected output speed under load. Use output torque, not only motor torque. Gearbox efficiency and backlash can change the result. Power provides a useful cross-check because it depends on torque and rotational speed. If either value is pushed too far, heat usually appears first.

I once chose a compact motor from its peak torque alone. It moved the mechanism, but repeated starts overheated the housing. The overlooked issue was duty cycle. Record run time, rest time, supply voltage, and ambient temperature during a realistic trial. Listen for gear noise and watch for speed drop when the load changes. Leave room for imperfect measurements, because friction rarely stays constant. A modest margin is safer than operating at the limit every cycle.

Select the Gearbox Type, Ratio, and Output Configuration

How to Choose the Right Miniature Gear Motor?
Select the Gearbox Type, Ratio, and Output Configuration

Gearbox selection begins with the load, not the motor’s advertised speed. Spur gears suit compact, low-cost mechanisms with moderate loads. Planetary gearboxes provide higher torque density and better load sharing. Worm gears offer high reduction, but friction can reduce efficiency and create heat. The first estimate is rarely perfect. A practical test should measure temperature, noise, and current after continuous operation.

Choose the ratio by matching required output speed and torque. For example, a 3,000 rpm motor with a 30:1 ratio produces roughly 100 rpm before losses. Allow extra torque capacity for startup, jams, and uneven loads. This matters because motor-driven systems consume approximately 50% of global electricity, according to the International Energy Agency’s Energy Efficiency 2023 report. In industrial facilities, motor systems can represent about 68% of electricity use, according to the U.S. Department of Energy’s motor-system sourcebook.

Output configuration deserves equal attention. A D-shaped shaft helps prevent slipping in light-duty assemblies. Keyed shafts handle stronger torque transfer. Hollow shafts can simplify alignment, while flange-mounted outputs improve structural support. Check shaft diameter, allowable radial load, axial load, and mounting clearances. A neat calculation can still mislead when the gearbox faces shock loads. Select the smallest unit that meets the real duty cycle, not only the no-load specification.

How to Choose the Right Miniature Gear Motor? - Select the Gearbox Type, Ratio, and Output Configuration

Gearbox Type Typical Ratio Range Typical Efficiency Typical Output Speed Typical Continuous Output Torque Best Application Fit Advantages Limitations Recommended Output Configuration
Spur Gearbox 4:1 to 300:1
Higher ratios may require multiple stages.
Approximately 65%–90%, depending on the number of stages, lubrication, and load. Approximately 10–3,000 rpm, depending on motor speed and selected ratio. Approximately 0.01–1.0 N·m for compact miniature designs. Cost-sensitive mechanisms, small pumps, valves, toys, indicators, and light-duty automation. Good general-purpose choice Simple construction, low cost, compact radial size, and good availability of standard ratios. Lower torque density than planetary designs; gear noise and backlash usually increase with ratio and wear. Round or D-shaped shaft for simple couplings; keyed shaft when positive torque transmission is required.
Planetary Gearbox 4:1 to 1,000:1
Usually assembled from multiple stages.
Approximately 75%–95%, depending on the number of stages and operating load. Approximately 5–4,000 rpm, depending on ratio and motor speed. Approximately 0.03–3.0 N·m for miniature designs. Robotics, precision positioning, compact actuators, medical mechanisms, and applications requiring high torque from a small package. Best for torque density High torque capacity, good load distribution, compact axial length, and generally lower backlash than basic spur arrangements. Higher cost, more complex construction, and efficiency decreases as additional stages are added. D-shaped, keyed, or splined output shaft for controlled torque transfer and repeatable positioning.
Worm Gearbox 10:1 to 300:1
High ratios can often be achieved in one stage.
Approximately 30%–75%, depending on lead angle, ratio, lubrication, and load. Approximately 2–500 rpm, depending on motor speed and ratio. Approximately 0.02–2.0 N·m for miniature designs. Compact right-angle drives, lifting mechanisms, small gates, dampers, and applications needing resistance to reverse motion. Best for right-angle and holding functions Right-angle output, high reduction in a compact arrangement, and potential self-locking at suitable low lead angles. Lower efficiency, greater heat generation, sliding wear, and self-locking is not guaranteed under every load or vibration condition. Hollow or solid right-angle output; keyed shaft is preferred for higher torque and anti-slip coupling.
Bevel Gearbox 3:1 to 100:1
Higher ratios normally require multiple stages.
Approximately 70%–92%, depending on gear geometry and stage count. Approximately 10–2,500 rpm, depending on the motor and selected ratio. Approximately 0.02–1.5 N·m for miniature designs. Right-angle motion transfer where higher efficiency and smoother operation are required than a typical worm drive. Best for efficient right-angle transmission Changes the direction of rotation by 90 degrees, provides better efficiency than worm gearing, and supports relatively high speed. More expensive and sensitive to alignment, assembly accuracy, lubrication, and bearing support. Solid keyed or D-shaped output shaft; use a supported shaft or flange when external radial loads are present.
Planetary-Spur Combination 20:1 to 1,500:1
Multiple stages are used for very high reduction.
Approximately 60%–90%, depending on the number and type of stages. Approximately 1–1,000 rpm, depending on the motor and total ratio. Approximately 0.05–4.0 N·m for selected miniature assemblies. Compact high-reduction actuators, small winches, robotic joints, and battery-powered mechanisms requiring both speed reduction and torque multiplication. Combines high planetary torque capacity with the high reduction capability of spur stages. Longer gearbox, increased backlash and efficiency loss across additional stages, and higher overall cost. Keyed or splined output for high-load applications; D-shaped output for lower-cost, moderate-load assemblies.
Typical miniature gear motor values are indicative engineering ranges rather than guaranteed ratings. Actual performance depends on motor size, supply voltage, duty cycle, lubrication, temperature, bearing arrangement, gear material, and allowable radial or axial load.
Selection guide: Choose the gearbox type according to the required torque density, efficiency, orientation, noise level, and holding behavior. Select the ratio using Required Gear Ratio = Motor No-Load Speed ÷ Required Output Speed. For continuous operation, keep the working torque and speed within the manufacturer's rated limits and allow sufficient margin for startup, stall, shock, and acceleration loads.

Evaluate Voltage, Control Method, Size, and Mounting Constraints

How to Choose the Right Miniature Gear Motor?

Voltage is the first filter, not a final decision. Match the motor’s rated voltage with the available supply, then check startup current. A 12 V motor may briefly draw several times its running current under load. According to the U.S. Department of Energy’s Motor Systems Sourcebook, motor-driven equipment represents a major share of industrial electricity use, so small efficiency losses can become expensive at scale. Measure the real load if possible. Catalog torque alone can mislead.

Control method changes motor behavior. Use simple on/off control for fixed-speed mechanisms. Choose PWM control when speed adjustment, soft starting, or quieter operation matters. For accurate positioning, a geared motor with feedback is safer than repeatedly guessing its shaft position. I have seen compact assemblies overheat because the controller limited speed but not current. That mistake is easy to miss.

Size must fit the mechanism, not just the drawing. Check gearbox diameter, shaft length, connector clearance, and the motor’s stall torque. IEC 60034-1 provides the broader framework for motor ratings, but miniature applications still require application testing. Mounting holes may align perfectly while the housing blocks a cable route. Leave room for service. A two-millimeter gap can prevent vibration damage, yet designers often treat it as wasted space. Recheck the assembly at maximum temperature, because grease, plastic parts, and bearing friction can change performance. Manufacturers’ test conditions are useful, but they rarely represent every real installation.

Compare Efficiency, Noise, Durability, and Total Operating Cost

How to Choose the Right Miniature Gear Motor?

Efficiency should be measured under the real load, not only from a specification sheet. A motor drawing 0.4 amps without load may consume much more when lifting a small mechanism. Test it at the target speed, torque, and duty cycle. Record current, temperature, and output speed after thirty minutes. Gear reduction improves torque, but every gear stage adds friction. This detail is easy to overlook.

Noise matters in offices, medical equipment, and compact consumer devices. Listen for both motor whine and gear clicking. A smooth sound at startup may become harsh after repeated reversals. Use a decibel meter at a fixed distance, because casual listening can be misleading. Soft mounts can reduce vibration, but they may also allow unwanted movement.

Durability depends on heat, load changes, lubrication, and alignment. Check shaft support, gearbox backlash, and the rated operating life. A motor running cooler often lasts longer, even when its purchase price is higher. Compare total operating cost, including energy, maintenance, replacement labor, and downtime. A cheaper motor can become expensive after several service calls. I have seen designs prioritize peak torque and ignore continuous duty. That mistake is common, and sometimes my own early estimates missed startup current. Build a small test fixture before committing to production.

FAQS

: What information should I define before choosing a miniature gear motor?

: Record the load, output speed, voltage, available space, and motion profile. Include startup torque, running torque, reversing frequency, and stall risk. Note run time and rest time. Small details matter.

How do I calculate the required output torque?

Measure the resisting force and shaft radius. For a small conveyor, torque equals force multiplied by pulley radius. Add friction, startup resistance, and a practical safety margin. Bench results can mislead.

Why must duty cycle be included?

A motor running for three seconds differs from one running continuously. Repeated starts can create heat before visible failure appears. Record operating time, rest time, load changes, and ambient temperature. I once ignored this. It was a poor choice.

How should speed and torque be matched?

Check output speed and torque under the real load. Do not rely only on no-load speed or peak torque. Excessive reduction may increase torque but reduce efficiency and response speed. Watch for speed drops.

Which gearbox type suits a compact mechanism?

Spur gears suit moderate loads and simple mechanisms. Planetary gears provide higher torque density and load sharing. Worm gears offer strong reduction but may create more friction and heat. Test temperature and noise.

How do I choose the gearbox ratio?

Divide the motor speed by the desired output speed for an initial estimate. A 3,000 rpm motor with a 30:1 ratio gives about 100 rpm before losses. Actual output changes with efficiency and load. Leave room for errors.

What output shaft design should I select?

A D-shaped shaft can reduce slipping in light-duty assemblies. Keyed shafts suit stronger torque transfer. Hollow shafts may simplify alignment. Flange mounting can improve structural support.

What mechanical details should I verify before installation?

Check shaft diameter, radial load, axial load, orientation, and mounting clearance. Inspect possible shock loads from jams or uneven movement. Measure gearbox backlash and listen for unusual noise. A neat calculation may still fail.

How should I test a selected miniature gear motor?

Run realistic start-stop cycles with the intended load. Measure current, temperature, speed, and housing heat. Test cold starts and changing resistance. Several hundred cycles reveal more than one clean bench test.

Conclusion

Choosing the right Miniature Gear Motor begins with a clear understanding of the application. Define the required motion, operating cycle, load characteristics, available space, and environmental conditions before comparing products. The motor’s speed, torque, and power should match the mechanical load, with enough margin to handle starting demands and occasional variations without unnecessary oversizing.

Next, select a gearbox type and reduction ratio that provide the desired output speed, torque, and direction, while considering the most suitable output shaft or mounting configuration. Check the available voltage, control method, dimensions, mounting points, and compatibility with the overall system. Finally, compare efficiency, operating noise, service life, heat generation, maintenance needs, and total operating cost. A well-balanced choice should deliver reliable performance over time rather than focusing only on initial price or maximum specifications.

Madeline

Madeline

Madeline is a dedicated marketing professional with a wealth of expertise in our company's core offerings. With a keen understanding of the industry, she brings a unique perspective to her role, consistently delivering high-quality content that highlights the superior aspects of our products. As......